
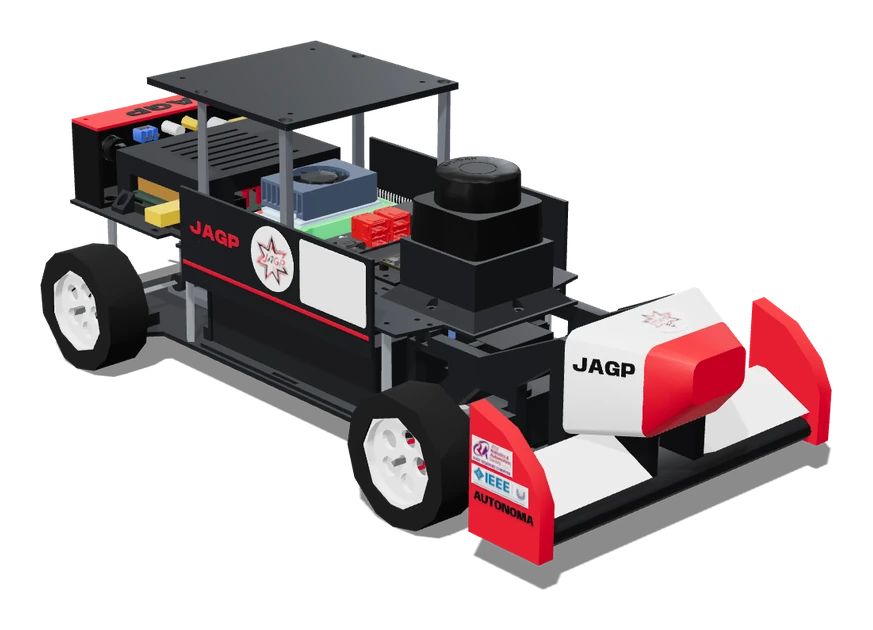
AUTONOMA · the organisers' car
Same car.Your code.
Every AUTONOMA team's software drives this car, one team at a time.
Design render, release 0.1. The car hasn't been built or tested yet.
No car to build. Nothing to bolt on.
The organisers build two identical cars: one races, the other is for testing and is the spare. Teams fit nothing to the car and can't add sensors. Your whole entry is software.
- Scale1:10
- DriveRear-wheel drive, one brushless motor
- LiDAR2D, Slamtec RPLIDAR C1
- MotionIMU, and wheel-speed odometry from the motor controller
- ComputerNVIDIA Jetson Orin Nano Super, Ubuntu 24.04, ROS 2 Jazzy
- SafetyHardware kill switch on the drive power, and the organiser's remote E-stop
As specified today. The design isn't finished: the specification is published with the simulator, and that published specification is the one that counts.
How a turn works
Press start. Then hands off.
There are no separate mapping sessions. Each turn, the car learns the layout and then races it, with nobody touching it in between.
- Your team
Tag your code
Your team has a private repository in the organisers' GitHub organisation. Tag the commit for the round before its deadline, and the organisers build your container image from it.
- Marshal
Load the image
At the track, the marshal loads your image onto the car.
- Your team
Press start
From this moment, nobody touches the car or its software.
- The car
Map the layout
Your software drives the car round and maps the layout.
- The car
Race the timed laps
Then it drives the timed laps. The organiser's emergency stop is the only input from outside.
What your software gets.
Your container receives the car's published sensor and state data, and it may send one thing back: the drive command. It has no network and no access to the motor controller.
The same container must run in the simulator. The simulator and the robot description (URDF) are released to registered teams when they are ready.
From every side.

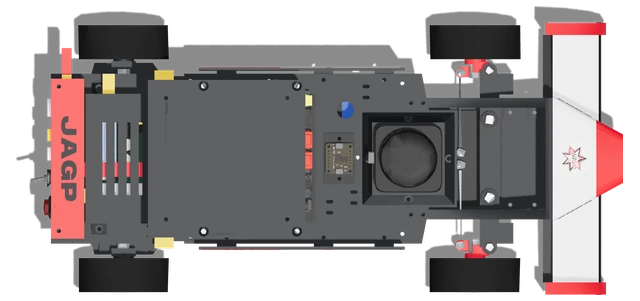
Drive it like it's yours.
If your software damages an organisers' car, your team pays for the repair. It's billed afterwards, with no deposit, and the Stewards decide whether the damage was caused by your software. This also applies during the practice period.
How the cost is assessed and collected will be published in the rulebook.